FOTIS INTER
กำลังโหลด · Loading…
กำลังโหลด · Loading…
FOTIS / MARINE / EMBEDDED FIRMWARE
Developing an RPM data path from CAN/NMEA2000 through ESP32 to GPS or COMBOX, with firmware and handover documentation.
Firmware development & field validation preparation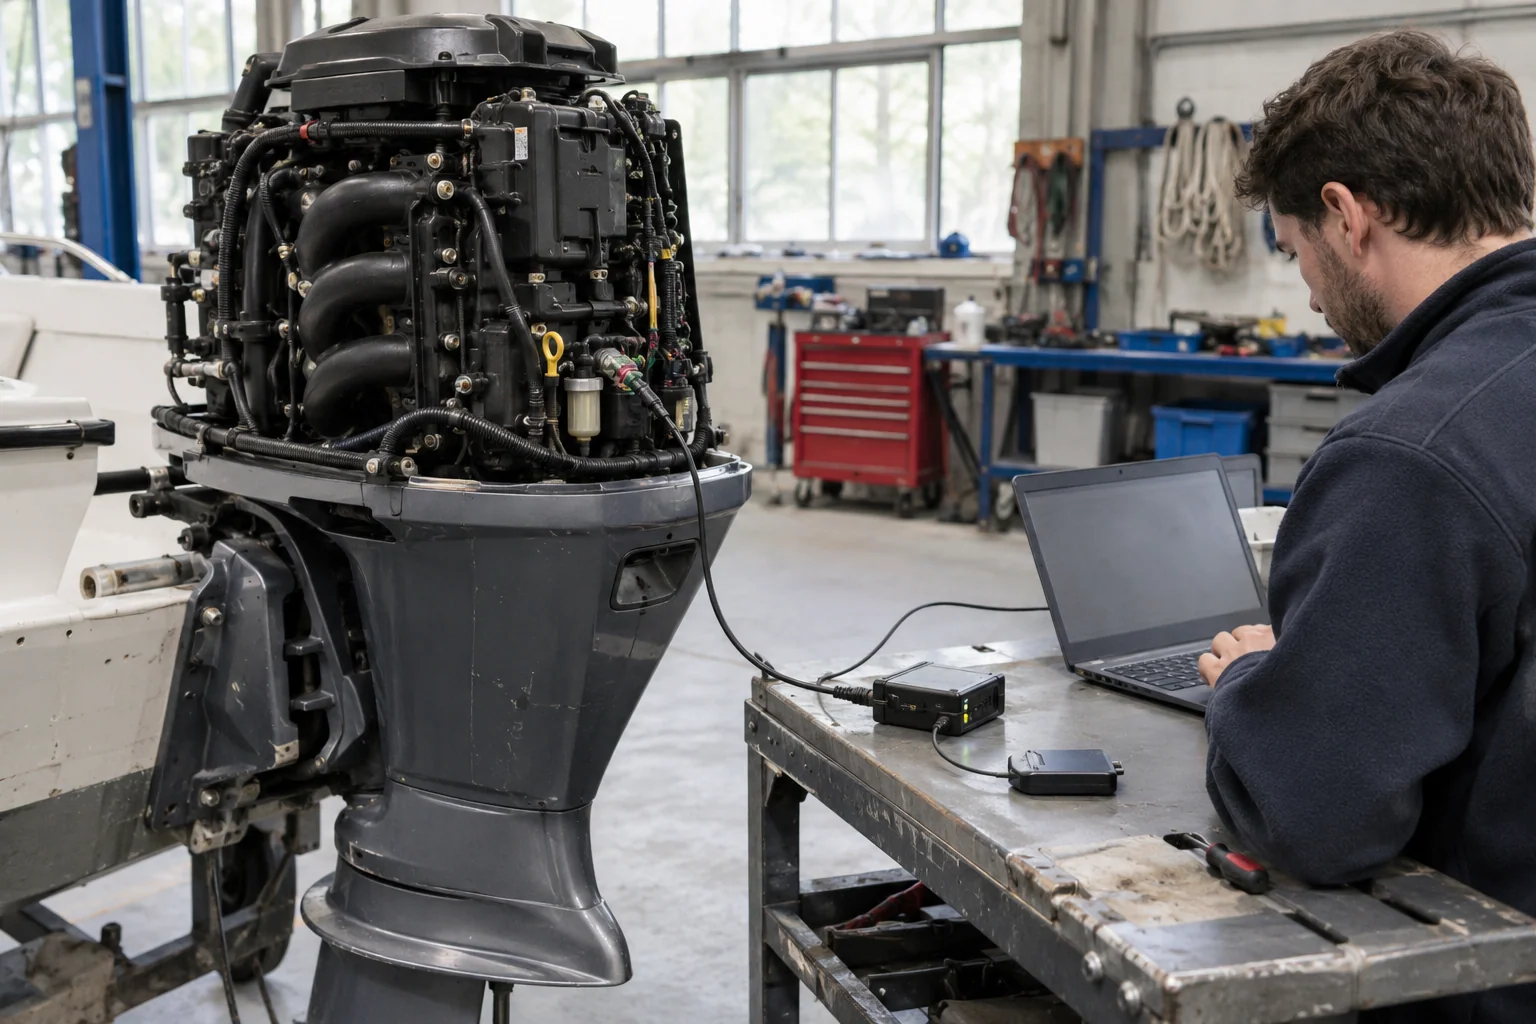
01 / THE OPERATING PROBLEM
Engineering work
Engine information and tracking systems use different interfaces. The integration must distinguish engine instances, decode supported signals and format the output for the receiving system.
02 / OUR CONTRIBUTION
We organize RPM decoding from CAN/NMEA2000, engine-instance handling and RS232 output, with CAN references, hardware guides, packet documentation and a field handover checklist.
03 / THE WORK PRODUCED
INFORMATION / OPERATING VALUE
04 / SOURCE MATERIAL
Drawing, document and interface excerpts with their source and scope. Enlarge a sample to inspect it.
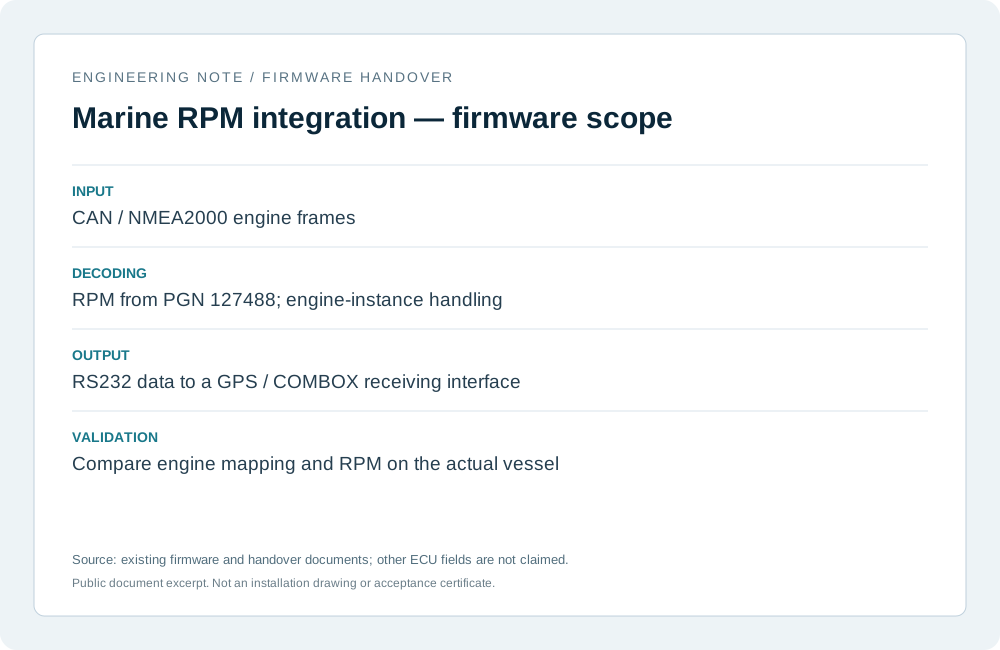
Firmware and handover-document extract
Summarises CAN/NMEA2000 → RPM decoding → RS232 from the existing firmware and guides, with actual-vessel validation identified separately.
Source: Honda Marine CAN Bus README, firmware and handover checklistDoes not claim full ECU-field support or completed validation of every engine instance.
CURRENT STATUS / SCOPE
The current firmware focuses on RPM. Temperature, gear and manufacturer-specific states need further development and validation; complete engine-instance coverage requires vessel testing.
Begin with a well-defined problem and available data, then agree the development work, device access and validation approach before expanding.
LET’S BUILD TOGETHER
Tell us about your process, existing equipment and the information your team needs. We can define the scope and the checks to make at your site.